Integration of multiple, heterogeneous sensors is a challenging problem across a range of applications. Prominent among these are multi-target tracking, where one must combine observations from different sensor types in a meaningful and efficient way to track multiple targets. Because different sensors have differing error models, we seek a theoretically justified quantification of the agreement among ensembles of sensors, both overall for a sensor collection, and also at a fine-grained level specifying pairwise and multi-way interactions among sensors. We demonstrate that the theory of mathematical sheaves provides a unified answer to this need, supporting both quantitative and qualitative data. Furthermore, the theory provides algorithms to globalize data across the network of deployed sensors, and to diagnose issues when the data do not globalize cleanly. We demonstrate and illustrate the utility of sheaf-based tracking models based on experimental data of a wild population of black bears in Asheville, North Carolina. A measurement model involving four sensors deployed among the bears and the team of scientists charged with tracking their location is deployed. This provides a sheaf-based integration model which is small enough to fully interpret, but of sufficient complexity to demonstrate the sheaf’s ability to recover a holistic picture of the locations and behaviors of both individual bears and the bear-human tracking system. A statistical approach was developed in parallel for comparison, a dynamic linear model which was estimated using a Kalman filter. This approach also recovered bear and human locations and sensor accuracies. When the observations are normalized into a common coordinate system, the structure of the dynamic linear observation model recapitulates the structure of the sheaf model, demonstrating the canonicity of the sheaf-based approach. However, when the observations are not so normalized, the sheaf model still remains valid.
How to Track the People Tracking YOU

Observ.ing - Observe nature. Own your data.
A decentralized platform for biodiversity observations, built on the AT Protocol.
What you can do with AT Protocol - Applied Meteorology
Years of centralized platforms have limited our thinking about what's possible on the web.
What you can do with AT Protocol - Applied Meteorology
Years of centralized platforms have limited our thinking about what's possible on the web.
Tutorial on Sheaves in Data Analytics : Lecture 1
Robotaxi Tracker — Tesla Robotaxi, Waymo & Zoox Fleet Data
Community-tracked statistics for Tesla Robotaxi, Waymo, and Zoox autonomous vehicle fleets: live wait times, fleet directories, service-area maps, pricing, and government safety data.
Unified framework for information integration based on information geometry
Significance Measuring the degree of causal influences among multiple elements of a system is a fundamental problem in physics and biology. We propose a unified framework for quantifying any combination of causal relationships between elements in a hierarchical manner based on information geometry. Our measure of integration, called geometrical integrated information, quantifies the strength of multiple causal influences among elements by projecting the probability distribution of a system onto a constrained manifold. This measure overcomes mathematical problems of existing measures and enables an intuitive understanding of the relationships between integrated information and other measures of causal influence such as transfer entropy. Inspired by the integration of neural activity in consciousness studies, our measure should have general utility in analyzing complex systems. , Assessment of causal influences is a ubiquitous and important subject across diverse research fields. Drawn from consciousness studies, integrated information is a measure that defines integration as the degree of causal influences among elements. Whereas pairwise causal influences between elements can be quantified with existing methods, quantifying multiple influences among many elements poses two major mathematical difficulties. First, overestimation occurs due to interdependence among influences if each influence is separately quantified in a part-based manner and then simply summed over. Second, it is difficult to isolate causal influences while avoiding noncausal confounding influences. To resolve these difficulties, we propose a theoretical framework based on information geometry for the quantification of multiple causal influences with a holistic approach. We derive a measure of integrated information, which is geometrically interpreted as the divergence between the actual probability distribution of a system and an approximated probability distribution where causal influences among elements are statistically disconnected. This framework provides intuitive geometric interpretations harmonizing various information theoretic measures in a unified manner, including mutual information, transfer entropy, stochastic interaction, and integrated information, each of which is characterized by how causal influences are disconnected. In addition to the mathematical assessment of consciousness, our framework should help to analyze causal relationships in complex systems in a complete and hierarchical manner.

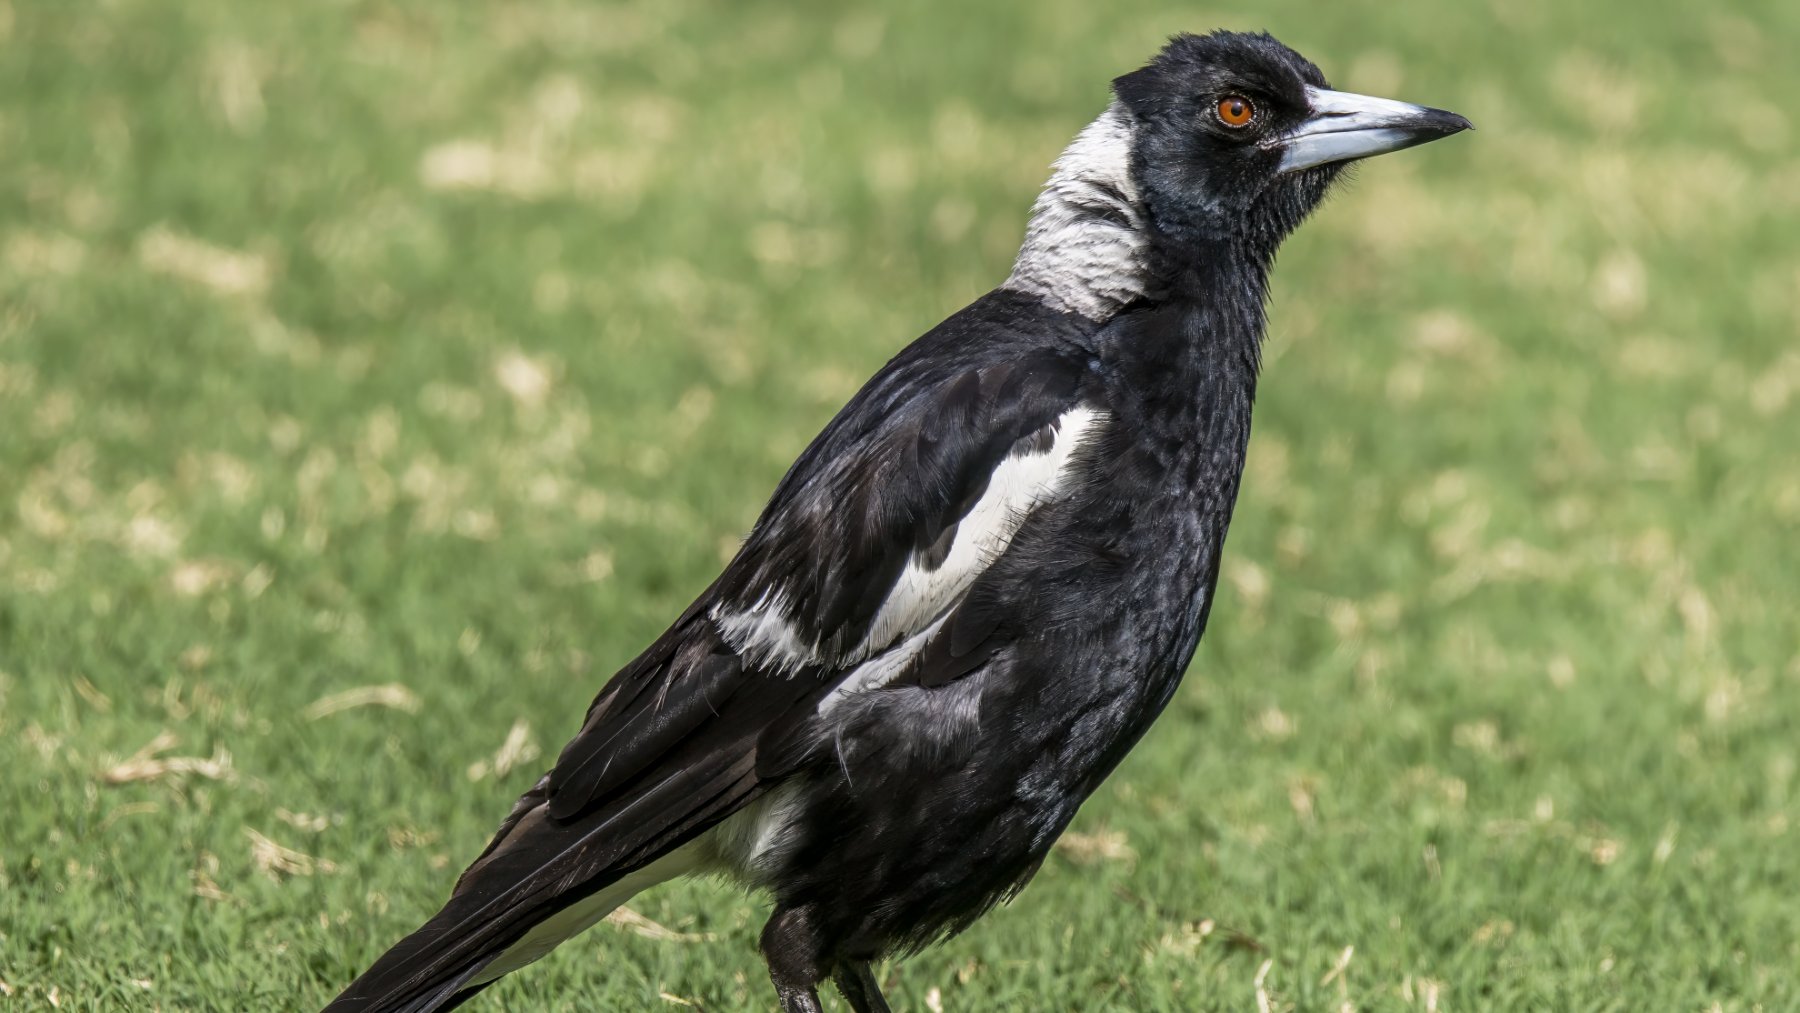
Researchers fitted five Australian magpies with GPS trackers to map their movements, but within an hour the birds began helping one another remove the harnesses, turning a failed tracking experiment into an unexpected observation of cooperation and problem-solving
Five Australian magpies helped each other remove their GPS harnesses within hours, ending a tracking study and revealing rare cooperative behaviour.
A Distributional Framework For Data Valuation
Shapley value is a classic notion from game theory, historically used to quantify the contributions of individuals within groups, and more recently applied to assign values to data points when training machine learning models. Despite its foundational role, a key limitation of the data Shapley framework is that it only provides valuations for points within a fixed data set. It does not account for statistical aspects of the data and does not give a way to reason about points outside the data set. To address these limitations, we propose a novel framework – distributional Shapley– where the value of a point is defined in the context of an underlying data distribution. We prove that distributional Shapley has several desirable statistical properties; for example, the values are stable under perturbations to the data points themselves and to the underlying data distribution. We leverage these properties to develop a new algorithm for estimating values from data, which comes with formal guarantees and runs two orders of magnitude faster than state-of-the-art algorithms for computing the (non distributional) data Shapley values. We apply distributional Shapley to diverse data sets and demonstrate its utility in a data market setting.
Where Durable Objects Live
Tracking where Durable Objects are created, wherever you are in the world.

ATsense: ATproto-style Federation for Open Sensor Networks (Draft)
ATsense: ATproto-style Federation for Open Sensor Networks (Draft) · GitHub

Robust Federated Inference
Federated inference, in the form of one-shot federated learning, edge ensembles, or federated ensembles, has emerged as an attractive solution to combine predictions from multiple models. This paradigm enables each model to remain local and proprietary while a central server queries them and aggregates predictions. Yet, the robustness of federated inference has been largely neglected, leaving them vulnerable to even simple attacks. To address this critical gap, we formalize the problem of robust federated inference and provide the first robustness analysis of this class of methods. Our analysis of averaging-based aggregators shows that the error of the aggregator is small either when the dissimilarity between honest responses is small or the margin between the two most probable classes is large. Moving beyond linear averaging, we show that problem of robust federated inference with non-linear aggregators can be cast as an adversarial machine learning problem. We then introduce an advanced technique using the DeepSet aggregation model, proposing a novel composition of adversarial training and test-time robust aggregation to robustify non-linear aggregators. Our composition yields significant improvements, surpassing existing robust aggregation methods by 4.7 - 22.2% in accuracy points across diverse benchmarks.

IO Factory: Simulating AI-Enabled Influence Campaigns at Scale
We introduce IO Factory, an AI-driven framework for simulating information and influence campaigns as fully integrated, traceable processes. The threat of digital manipulation now extends beyond persuasive text from individual language models to AI swarms, i.e., persistent groups of coordinated agents that adapt to platform feedback and disguise organized campaigns as ordinary social interaction. Because such campaigns cannot be identified from isolated messages alone, they must be analyzed across a continuous spectrum of planning, platform action, exposure, interpretation, measurement, and adaptation. IO Factory represents this process inside a controlled simulated platform, linking actor roles, platform actions, exposure records, structured model-based evaluations, and configured changes in the simulated population. We implement the architecture and evaluate it across configurations of up to 100,000 agents. The results show that IO Factory executes campaign timelines at scale and produces inspectable evidence of exposure and measured movement in configured belief variables. By recording the actors, objectives, action constraints, exposure paths, and measurement rules used in each run, IO Factory supports reproducible research and red-team analysis of coordinated influence.
MetaCOG: A Hierarchical Probabilistic Model for Learning Meta-Cognitive Visual Representations
Humans have the capacity to question what we see and to recognize when our vision is unreliable (e.g., when we realize that we are experiencing a visual illusion). Inspired by this capacity, we present MetaCOG: a hierarchical probabilistic model that can be attached to a neural object detector to monitor its outputs and determine their reliability. MetaCOG achieves this by learning a probabilistic model of the object detector's performance via Bayesian inference -- i.e., a meta-cognitive representation of the network's propensity to hallucinate or miss different object categories. Given a set of video frames processed by an object detector, MetaCOG performs joint inference over the underlying 3D scene and the detector's performance, grounding inference on a basic assumption of object permanence. Paired with three neural object detectors, we show that MetaCOG accurately recovers each detector's performance parameters and improves the overall system's accuracy. We additionally show that MetaCOG is robust to varying levels of error in object detector outputs, showing proof-of-concept for a novel approach to the problem of detecting and correcting errors in vision systems when ground-truth is not available.
Human sensor network
Human sensor networks provide real-time feedback, which is essential to managing complexity and can be used to help identify potential solutions to be explored, tested, and monitored. Networks created for ordinary monitoring or exploration can then be deployed in times of extraordinary need – when a natural disaster or a pandemic hits, a trusted network providing a real-time situational assessment might be readily available to deploy or tap into.