

Turn raw robot data into exact, tested, and versioned datasets for training and evaluation. Search synchronized streams down to the moment and stream reviewed windows directly to GPUs.
Introducing Index: Building The World’s Largest and Most Diverse Physical Dataset
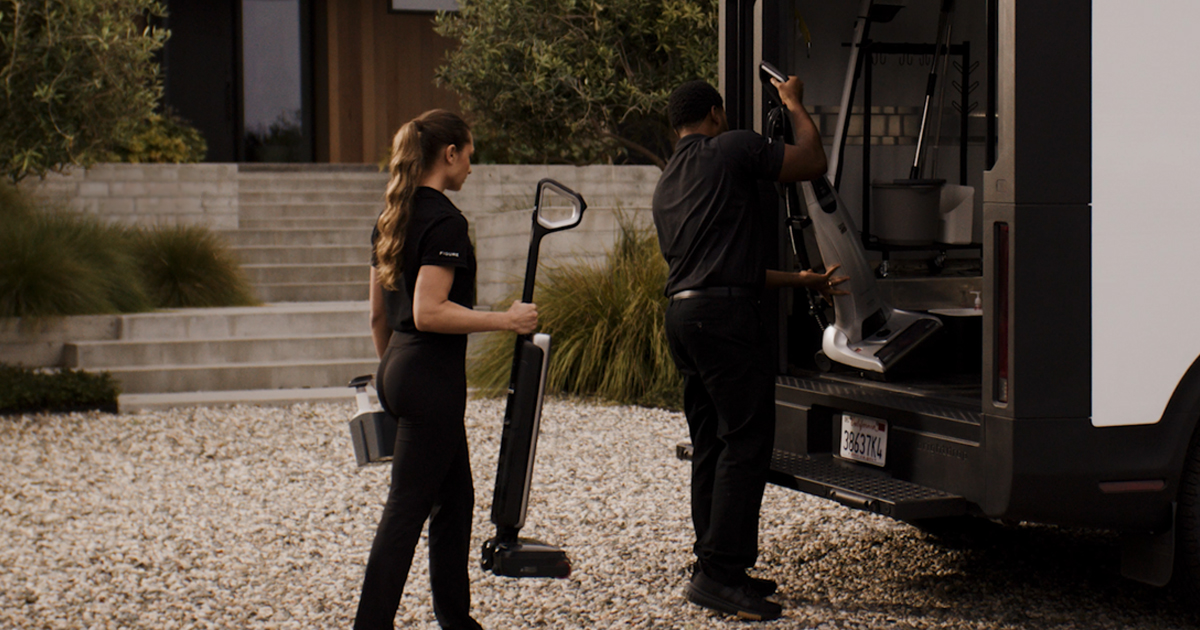
Today we're coming out of stealth with the largest robot training dataset ever built. The data needed to scale general robotics doesn't exist on the internet - it has to come from the real world: a global sampling of physics captured across every environment on earth.
Unsloth AI on Twitter / X
Introducing Unsloth Desktop 🦥The first desktop app to run and train models locally.• Open-source. Runs on Mac, Windows and Linux• Supports MLX, diffusion image/video, audio, GGUF• Connect Claude Code and Codex to local LLMs• 50% more accurate, self-healing tool calls +… pic.twitter.com/vjTFB1e5IQ— Unsloth AI (@UnslothAI) August 11, 2026

bytedance/UI-TARS-desktop
The Open-Source Multimodal AI Agent Stack: Connecting Cutting-Edge AI Models and Agent Infra
Motion Core — Svelte-native motion toolkit with GSAP and OGL-powered components, demos, and CLI-driven workflows
Svelte-native motion toolkit with GSAP and OGL-powered components, demos, and CLI-driven workflows.
Ollama's new engine for multimodal models· Ollama Blog
Ollama now supports new multimodal models with its new engine.
Radial
Coordinate humans and coding agents on software goals. Every unit of agent work is requested by a human and lands as a signed, reviewable artifact in its author’s own atproto repo — no central server.
Scaling long-running autonomous coding · Cursor
We've been experimenting with running coding agents autonomously for weeks at a time.
APRIL Laboratory APRIL Papers : Autonomy * Perception * Robotics * Interfaces * Learning
Crazy Roomba — Small robot. Big trouble.
Boost, drift, and vacuum your way from a tiny apartment to the moon. Play Crazy Roomba in your browser and race the daily leaderboard.
🚀🚀🚀 Excited to share that our Brain&AI team is releasing NeuralSet! 🚀🚀🚀 A fast, simple, and scalable package for Neuro-AI: 📦 `pip install neuralset` 💻 Code: https://lnkd.in/eamwxBUY 📄… | Jarod Lévy | 12 comments
🚀🚀🚀 Excited to share that our Brain&AI team is releasing NeuralSet! 🚀🚀🚀 A fast, simple, and scalable package for Neuro-AI: 📦 `pip install neuralset` 💻 Code: https://lnkd.in/eamwxBUY 📄 Paper: https://lnkd.in/epbreyDy As a PhD student working extensively with neuro recordings and AI models, I find this library to be a game-changer. This has been the common backbone for the past several years of our projects (TribeV2, DynaDiff, Brain2Qwerty & more!). This library turns raw neuro-recordings into AI-ready tensors. It enables: - Event-driven processing with typed, validated DataFrames. - Multimodal extractors for fMRI, EEG, MEG, EMG, and iEEG + text, image, audio, and video. - Torch-native segmentation for efficient batching. - Caching and remote compute through exca. Huge thanks to everyone on the team who made this release possible. If you're working on brain decoding, encoding models, or foundation models for neuroscience, don’t miss this! 🧠 Jean-Rémi King Hubert Banville Katie Begany Corentin Bel Yohann Benchetrit Teon Brooks Marlène Careil Simon Dahan Stéphane d'Ascoli Alexandre Défossez Linnea Evanson, PhD Pablo J. Diego Simón, Julien Gadonneix, Sophia Houhamdi Shubh Khanna Pierre Orhan Antoine Ratouchniak Joséphine Raugel Andrea Elena Santos Revilla Alexis Thual Lucy (Mingfang) Zhang Jérémy RAPIN | 12 comments on LinkedIn

robot.wtf — Memory for agents in a wiki for humans
Free, git-backed wiki hosting with native MCP support and semantic search. Sign in with Bluesky, create a wiki, connect your AI agents.
Understanding Multimodal LLMs
An introduction to the main techniques and latest models
MolmoAct 2: An open foundation for robots that work in the real world | Ai2
MolmoAct 2 is a fully open robotics foundation model that brings faster, stronger 3D action reasoning to real-world robot tasks, alongside a major new bimanual manipulation dataset for researchers to study, reproduce, and build on.
LettaBot - Your personal AI that remembers
Your personal AI with living memory. Remembers everything. Runs on your computer. Grows with you.
Inside the World's Smartest Robot Brain [VLA]
SwarmChat: An LLM-Based, Context-Aware Multimodal Interaction System for Robotic Swarms
Traditional Human-Swarm Interaction (HSI) methods often lack intuitive real-time adaptive interfaces, making decision making slower and increasing cognitive load while limiting command flexibility. To solve this, we present SwarmChat, a context-aware, multimodal interaction system powered by Large Language Models (LLMs). SwarmChat enables users to issue natural language commands to robotic swarms using multiple modalities, such as text, voice, or teleoperation. The system integrates four LLM-based modules: Context Generator, Intent Recognition, Task Planner, and Modality Selector. These modules collaboratively generate context from keywords, detect user intent, adapt commands based on real-time robot state, and suggest optimal communication modalities. Its three-layer architecture offers a dynamic interface with both fixed and customizable command options, supporting flexible control while optimizing cognitive effort. The preliminary evaluation also shows that the SwarmChat's LLM modules provide accurate context interpretation, relevant intent recognition, and effective command delivery, achieving high user satisfaction.
