OpenAI goal is to build a world simulator - that learns the dynamics of the 3D real world - from videos & language descriptions.They claim the work indicates that training on ever larger datasets is a promising direction for learning such world models.But they are wrong:— Chomba Bupe (@ChombaBupe) February 16, 2024
OpenAI seeks to improve AI with broader training data
OpenAI's new Data Partnerships seek to diversify AI training data to reflect diverse languages, cultures and topics beyond scraped data.

RoboScape: Physics-informed Embodied World Model
World models have become indispensable tools for embodied intelligence, serving as powerful simulators capable of generating realistic robotic videos while addressing critical data scarcity challenges. However, current embodied world models exhibit limited physical awareness, particularly in modeling 3D geometry and motion dynamics, resulting in unrealistic video generation for contact-rich robotic scenarios. In this paper, we present RoboScape, a unified physics-informed world model that jointly learns RGB video generation and physics knowledge within an integrated framework. We introduce two key physics-informed joint training tasks: temporal depth prediction that enhances 3D geometric consistency in video rendering, and keypoint dynamics learning that implicitly encodes physical properties (e.g., object shape and material characteristics) while improving complex motion modeling. Extensive experiments demonstrate that RoboScape generates videos with superior visual fidelity and physical plausibility across diverse robotic scenarios. We further validate its practical utility through downstream applications including robotic policy training with generated data and policy evaluation. Our work provides new insights for building efficient physics-informed world models to advance embodied intelligence research. The code is available at: https://github.com/tsinghua-fib-lab/RoboScape.
OpenAI peeks into the “black box” of neural networks with new research
We do not understand" how LLMs work, admits OpenAI in quest to make them interpretable.

OpenAI changed AI Video FOREVER | Sasha Grey
After 600 experiments, here's what I discovered about JEPA world models
There's a big debate in AI right now about what a world model should be. Most of the attention goes to generative world models, which predict the future by generating it, usually in pixels.

WorldClaw: Agentic 3D Open-World Generation at Scale
From one open-ended prompt to an explicit, explorable, and editable 3D world.
OpenAI to acquire Neptune
OpenAI is acquiring Neptune to deepen visibility into model behavior and strengthen the tools researchers use to track experiments and monitor training.
OpenAI launches new AI model for life sciences research
Researchers are drowning in data. AI could help.
Introducing Index: Building The World’s Largest and Most Diverse Physical Dataset
Today we're coming out of stealth with the largest robot training dataset ever built. The data needed to scale general robotics doesn't exist on the internet - it has to come from the real world: a global sampling of physics captured across every environment on earth.
Olmo 3: Charting a path through the model flow to lead open-source AI | Ai2
Our new flagship Olmo 3 model family empowers the open source community with not only state-of-the-art open models, but the entire model flow and full traceability back to training data.

Data Commons Can Save Open AI
Recent progress in open datasets shows promise for building fully open AI models without legal constraints.

Kimi K3 Tech Blog: Open Frontier Intelligence
Kimi K3 is the world's first open 3T-class model — frontier performance across coding, knowledge work, and reasoning, with native multimodality and 1M context.
GPT-4
We’ve created GPT-4, the latest milestone in OpenAI’s effort in scaling up deep learning. GPT-4 is a large multimodal model (accepting image and text inputs, emitting text outputs) that, while less capable than humans in many real-world scenarios, exhibits human-level performance on various professional and academic benchmarks.
World Emulation via Neural Network
I turned a forest trail near my apartment into a playable neural world. You can explore that world in your web browser by clicking right here:
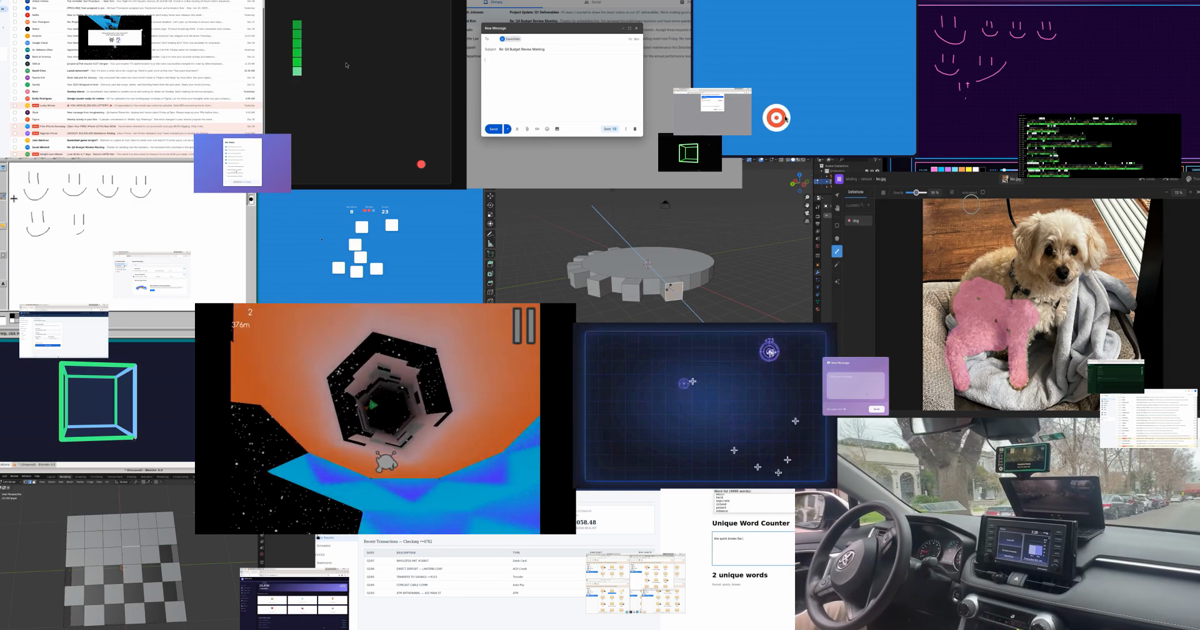
The First Fully General Computer Action Model
We trained a model on our 11-million-hour video dataset. Our model can explore complex websites, complete multi-action CAD modeling sequences, and drive a car in the real world, all at 30 FPS.
Find Open Datasets for AI and Research | Kaggle
Browse and download hundreds of thousands of open datasets for AI research, model training, and analysis. Join a community of millions of researchers, developers, and builders to share and collaborate on Kaggle.